
1. Introduction
The CHUNYE ARM-21N4 is a 5-Degrees-of-Freedom (DOF) robot arm kit designed for enthusiasts and educational purposes. This mechanical arm is suitable for various applications, including self-learning, drawing, and imitation tasks. It features robust construction with all movable joints connected by bearings, ensuring smooth and precise movements. This manual provides essential information for the assembly, operation, and maintenance of your robot arm.
The kit is available with either 20KG or 25KG digital servos, offering different levels of torque capacity. The gripper holder is versatile, accommodating various end effectors such as suction cups, electromagnets, forks, or craws.
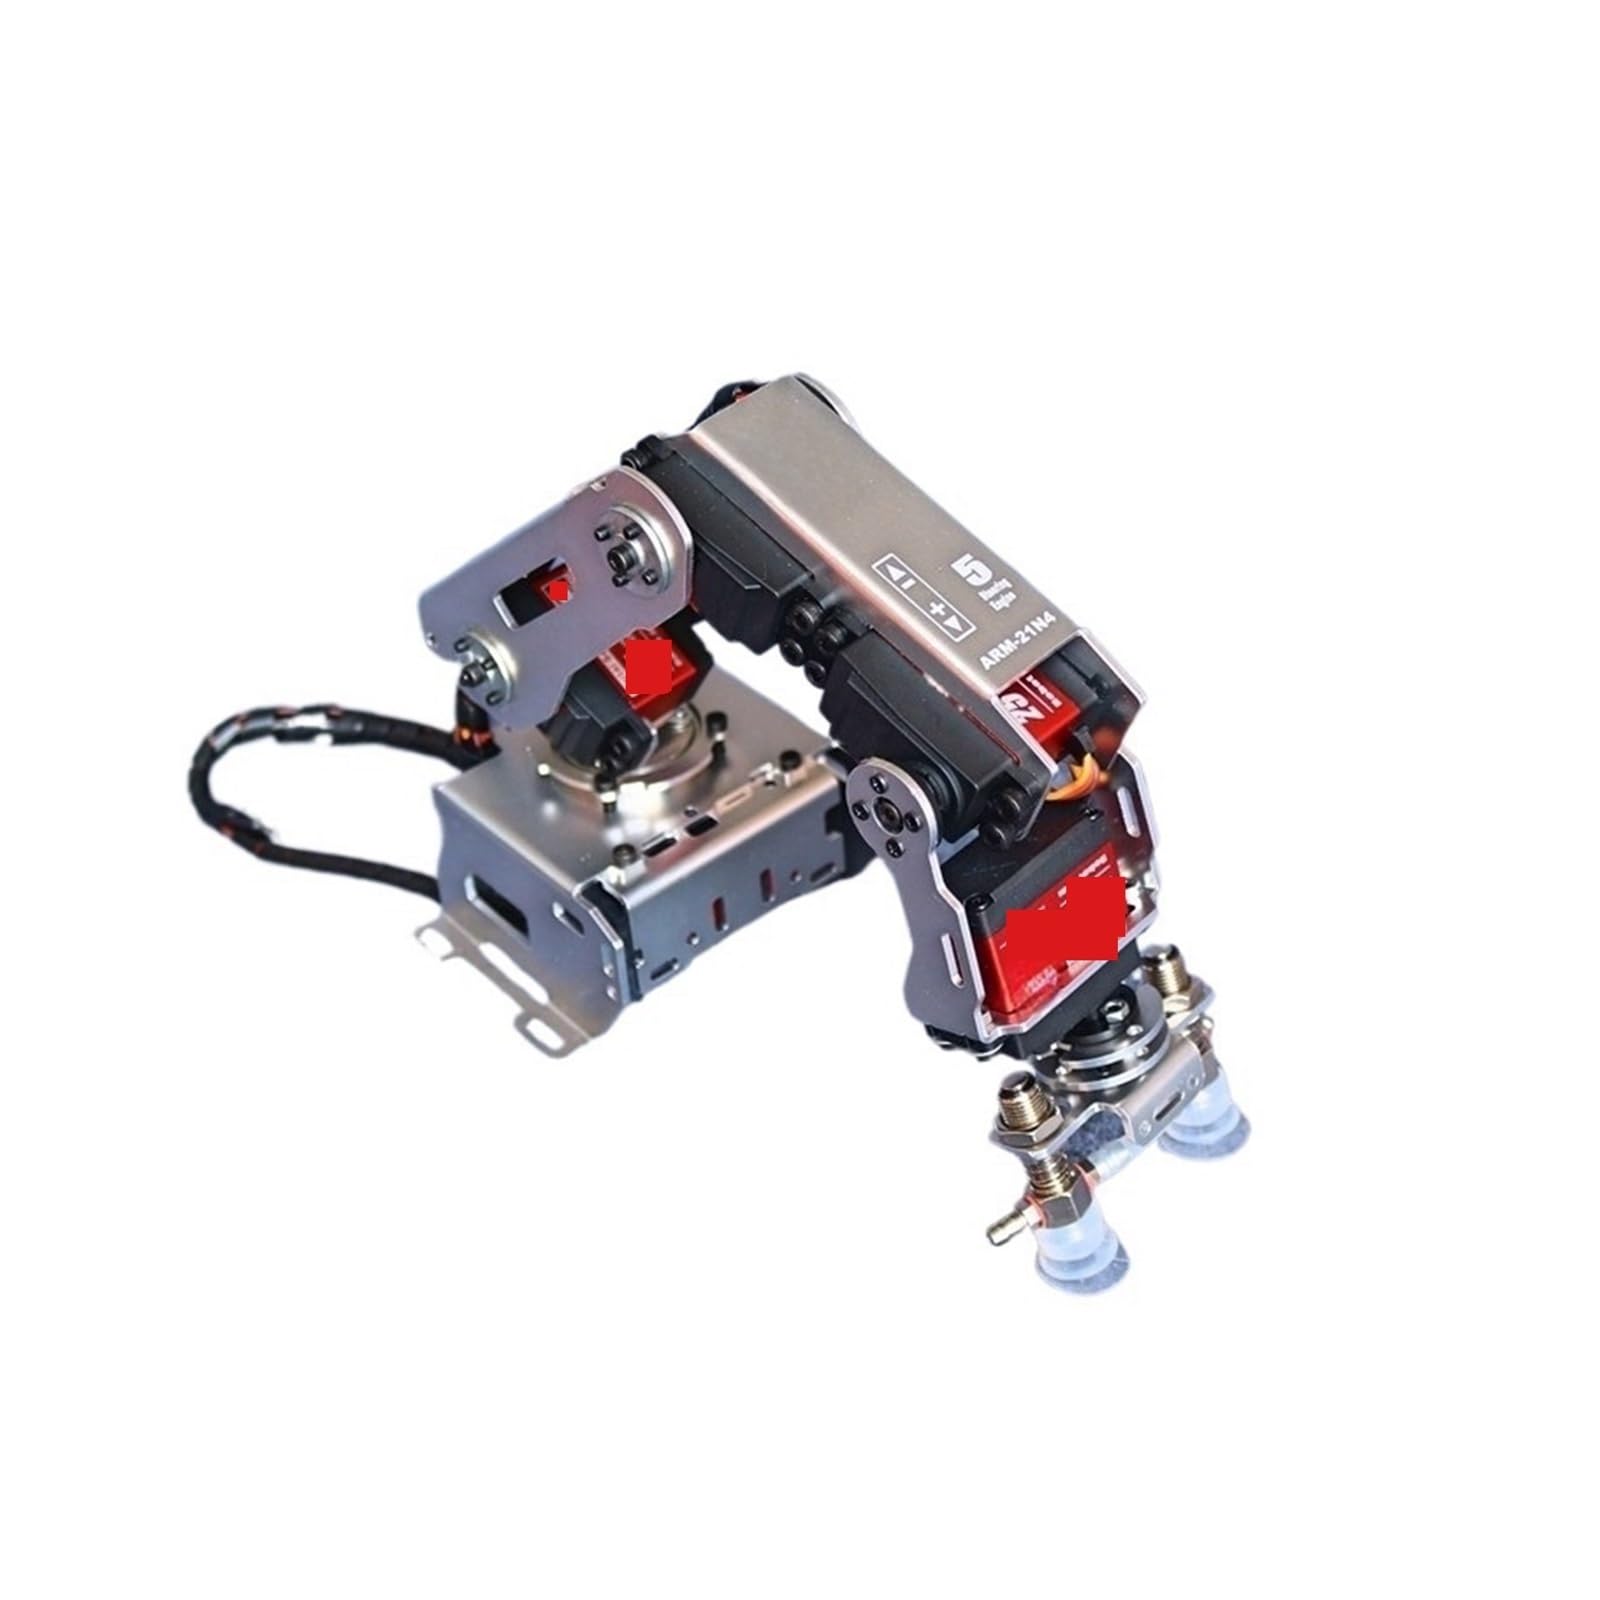
Figure 1: Assembled CHUNYE ARM-21N4 Robot Arm Kit.
2. Safety Information
- Read Instructions Carefully: Before assembly or operation, thoroughly read and understand all instructions in this manual.
- Adult Supervision: This product is recommended for adult users or requires adult supervision during assembly and operation, especially for younger users.
- Power Supply: Ensure the power supply used is appropriate for the digital servos (4.8-7.2V, instant 8.2V for 25KG servo). Incorrect voltage can damage components.
- Moving Parts: Keep hands, hair, and loose clothing clear of all moving parts during operation to prevent injury.
- Stable Surface: Operate the robot arm on a stable, level surface to prevent tipping or accidental movement.
- Electrical Connections: Double-check all electrical connections before applying power. Loose connections can cause malfunctions or damage.
- Environmental Conditions: Avoid operating the robot arm in wet or excessively dusty environments.
3. Package Contents
Verify that all components listed below are present in your package:
- 1 x Set of Robot Arm Mechanical Components
- Digital Servos (20KG or 25KG, depending on your purchased variant)
- Necessary Fasteners (screws, nuts, etc.)
- Wiring for Servos
Note: The kit is unassembled. Additional tools (e.g., screwdrivers, pliers) may be required for assembly and are not included.
4. Setup and Assembly
The ARM-21N4 robot arm kit requires assembly. Follow these general steps. Specific detailed diagrams may be provided separately or can be requested from support.
- Unpack Components: Carefully unpack all parts and lay them out on a clean, organized workspace. Identify the main structural components, servos, and fasteners.
- Assemble Base: Begin by assembling the base structure of the robot arm. Secure the bottom plate to the vertical support using the provided screws.
- Install Base Servo: Mount the first digital servo into the base assembly. This servo controls the arm's rotation. Ensure it is securely fastened and its output shaft is correctly oriented.
- Attach Lower Arm Section: Connect the lower arm segment to the base servo's output shaft. Use the appropriate fasteners to ensure a firm connection that allows for smooth rotation.
- Install Remaining Servos and Arm Segments: Proceed to install the remaining digital servos into their respective arm segments (upper arm, middle arm, forearm). Connect each arm segment sequentially, ensuring all joints are properly aligned and secured with bearings and fasteners.
- Attach Gripper Holder: Mount the gripper holder to the end of the forearm. This component is designed to attach various end effectors.
- Connect Wiring: Carefully connect the wiring from each servo to your chosen control board or power supply. Pay close attention to polarity and ensure all connections are firm.
- Initial Power-Up: Before full operation, perform a low-power test to ensure all servos respond correctly and there are no mechanical obstructions.

Figure 2: Assembled ARM-21N4 with a suction cup gripper attached.
5. Operating Instructions
The CHUNYE ARM-21N4 robot arm is designed for flexible control and various applications. Its operation depends on the control method and programming environment you choose.
- Control Methods: The robot arm supports multiple control methods. This typically involves connecting the servos to a microcontroller (e.g., Arduino, Raspberry Pi) and programming it to send pulse width modulation (PWM) signals to control each servo's position.
- Programming: Utilize programming languages like Python, C++, or visual programming tools to define the arm's movements, sequences, and tasks. The 5-DOF allows for complex movements and precise positioning.
- Features: Explore features such as self-learning, drawing, and imitation. These often require advanced programming and sensor integration (not included in the basic kit).
- Calibration: Before precise operations, calibrate each servo to ensure its full range of motion is utilized and its neutral position is correctly set.
- Experimentation: The ARM-21N4 is an excellent platform for experimenting with robotics and coding. Start with simple movements and gradually increase complexity.
6. Maintenance
Proper maintenance ensures the longevity and optimal performance of your robot arm.
- Regular Inspection: Periodically inspect all joints, screws, and electrical connections for looseness or wear. Tighten any loose fasteners.
- Cleaning: Keep the robot arm clean and free from dust and debris. Use a soft, dry cloth for cleaning. Avoid using harsh chemicals or abrasive materials.
- Lubrication: The bearings are designed for smooth operation. If any joint feels stiff, consult technical support for recommended lubrication methods.
- Servo Care: Avoid over-stressing the servos by attempting to move the arm beyond its physical limits or by applying excessive external force.
- Storage: When not in use, store the robot arm in a dry, clean environment away from extreme temperatures.
7. Troubleshooting
If you encounter issues with your ARM-21N4 robot arm, refer to the following common problems and solutions:
- Arm Not Moving:
- Check power supply connections and ensure it is providing adequate voltage and current.
- Verify all servo connections to the control board are correct and secure.
- Ensure your control program is running and sending the correct signals to the servos.
- Inspect for any mechanical obstructions preventing movement.
- Erratic Movement:
- Check for loose wiring or faulty connections.
- Ensure the power supply is stable and not fluctuating.
- Review your control code for logical errors or incorrect servo commands.
- Calibrate the servos if they are not returning to their expected positions.
- Servo Overheating:
- Reduce the load on the arm. The servos may be struggling with excessive weight or resistance.
- Ensure the arm is moving freely and not binding at any joint.
- Verify the power supply voltage is within the specified range.
If these steps do not resolve the issue, please contact our technical support team for further assistance.
8. Specifications
Detailed specifications for the ARM-21N4 robot arm and its digital servos:
| Feature | Description |
|---|---|
| Model | ARM-21N4 |
| Degrees of Freedom (DOF) | 5 |
| Joints | All movable joints connected by bearings |
| Upper Arm Length | 121mm (4.8") |
| Middle Arm Length | 111mm (4.4") |
| Forearm Length | 61mm (2.4") |
| Gripper Holder | Fits suction cups, electromagnets, forks, craws, grippers, etc. |
| Material Type | Metal (aluminum alloy) + Plastic |
| Assembly Required | Yes (Unassembled kit) |
| Operation Mode | Manual (via external controller/programming) |
| Item Weight | Approximately 1000 Grams (total kit) |
Digital Servo Specifications (20KG Version)
| Feature | Description |
|---|---|
| Servo Board | Digital controller |
| Servo Size | 40 x 20.5 x 40.5mm (1.6 x 0.8 x 1.6") |
| Weight | 56g ±5% (0.1lb ±5%) |
| Working Voltage | 4.8-7.2V |
| Output Transmission | Metal gears + double bearings |
| No-load Speed | 0.14-0.18sec/60° |
| Stall Torque | 20.5kg.cm |
| Pulse Width | 500-2500usec |
| Rotation Angle | 180° |
| Dead Zone Width | 5usec |
| Midpoint Position | 1500usec |
| Output Shaft | 25T |
| Output Shaft Hole | M3 |
| Idling Current | 210-260mA |
| Blocking Current | 2100-2700mA |
| Waterproof Level | Preliminary |
| Body Shell | Aluminum alloy + plastic |
Digital Servo Specifications (25KG Version)
| Feature | Description |
|---|---|
| Servo Board | Digital controller |
| Servo Dimensions | 40 x 20.5 x 40.5mm (1.6 x 0.8 x 1.6") |
| Weight | 62g ±5% (0.1lb ±5%) |
| Working Voltage | 4.8-7.2V (instant 8.2V) |
| Output Transmission | Metal gears + double bearings |
| No-load Speed | 0.145-0.185sec/60° |
| Stall Torque | 25.5kg.cm |
| Pulse Width | 500-2500usec |
| Rotation Angle | 180° |
| Dead Zone Width | 5usec |
| Midpoint Position | 1500usec |
| Output Shaft | 25T |
| Output Shaft Hole | M3 |
| Idling Current | 220-280mA |
| Blocking Current | 2250-2850mA |
| Waterproof Level | Preliminary |
| Body Shell | Aluminum alloy (red) + plastic (black) |
9. Warranty and Support
We are committed to providing high-quality products and excellent customer service. Your CHUNYE ARM-21N4 Robot Arm Kit comes with a service guarantee.
- Technical Support: We have a professional technical support team available to provide fast assistance. If you encounter any problems during use, please do not hesitate to contact us. We aim to reply within 24 hours.
- Missing Manual/Guide: If your item did not come with a guide or manual, please contact us for assistance.
- Contact Information: For support, please refer to the contact details provided on your purchase platform or the official CHUNYE website.